Penn State / 2022–2024
Gait analysis for exoskeleton-assisted walking
LSTM-based gait analysis and OpenSim workflows for exoskeleton-assisted walking.
LSTM models identify heel-strike and toe-off events during exoskeleton-assisted walking using ground reaction forces and heel-marker data. The work was published in PLOS ONE in 2025, with code and sample data available through Penn State Data Commons.
Advisor: Anne Martin · Penn State
Methods
LSTM models use ground reaction forces and heel-marker trajectories to identify heel-strike and toe-off events. Complementary MATLAB workflows connect Vicon and OpenSim for inverse kinematics and inverse dynamics of exoskeleton-assisted walking.

Gait-event detection

OpenSim workflows
Data conversion and batch-processing tools support kinematic and dynamic analysis and verification of exoskeleton walking trials.
Inverse dynamics tutorial ↓
OpenSim · Exoskeleton walking simulation
Research question and quantitative results
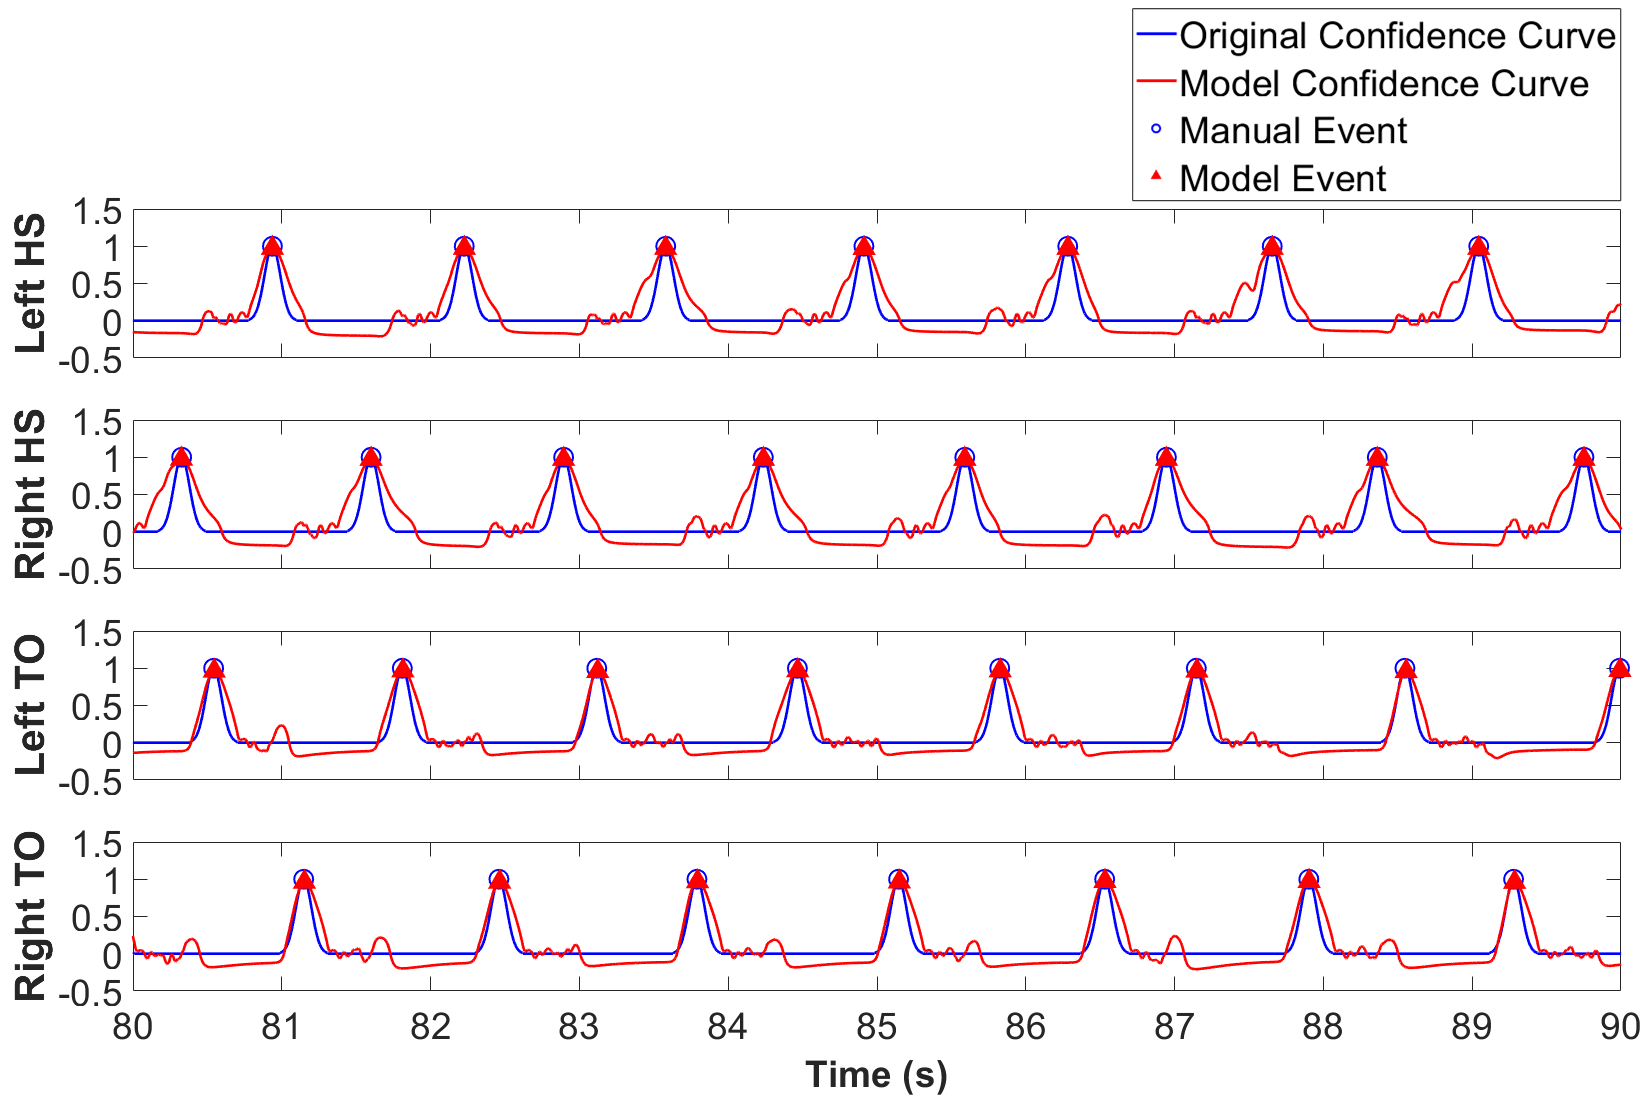
Exoskeleton-assisted walking alters gait and kinematic patterns, challenging conventional event-detection methods. The 2023–2024 study trained two separate LSTM models using ground reaction force and heel-marker kinematic data to detect heel strike (HS) and toe off (TO).
The study analyzed 113,236 gait events. Relative to manual annotations, more than 98% of HS events and 99% of TO events were detected within ±16 ms. These percentages describe detection performance within a specified timing tolerance, rather than error-free event timing. The traces and histograms below show event detections and timing-error distributions.
The study was published in PLOS ONE in 2025. MATLAB code and sample data are available through Penn State Data Commons for reuse and inspection.
Exoskeleton modeling and data processing (2022–2023)
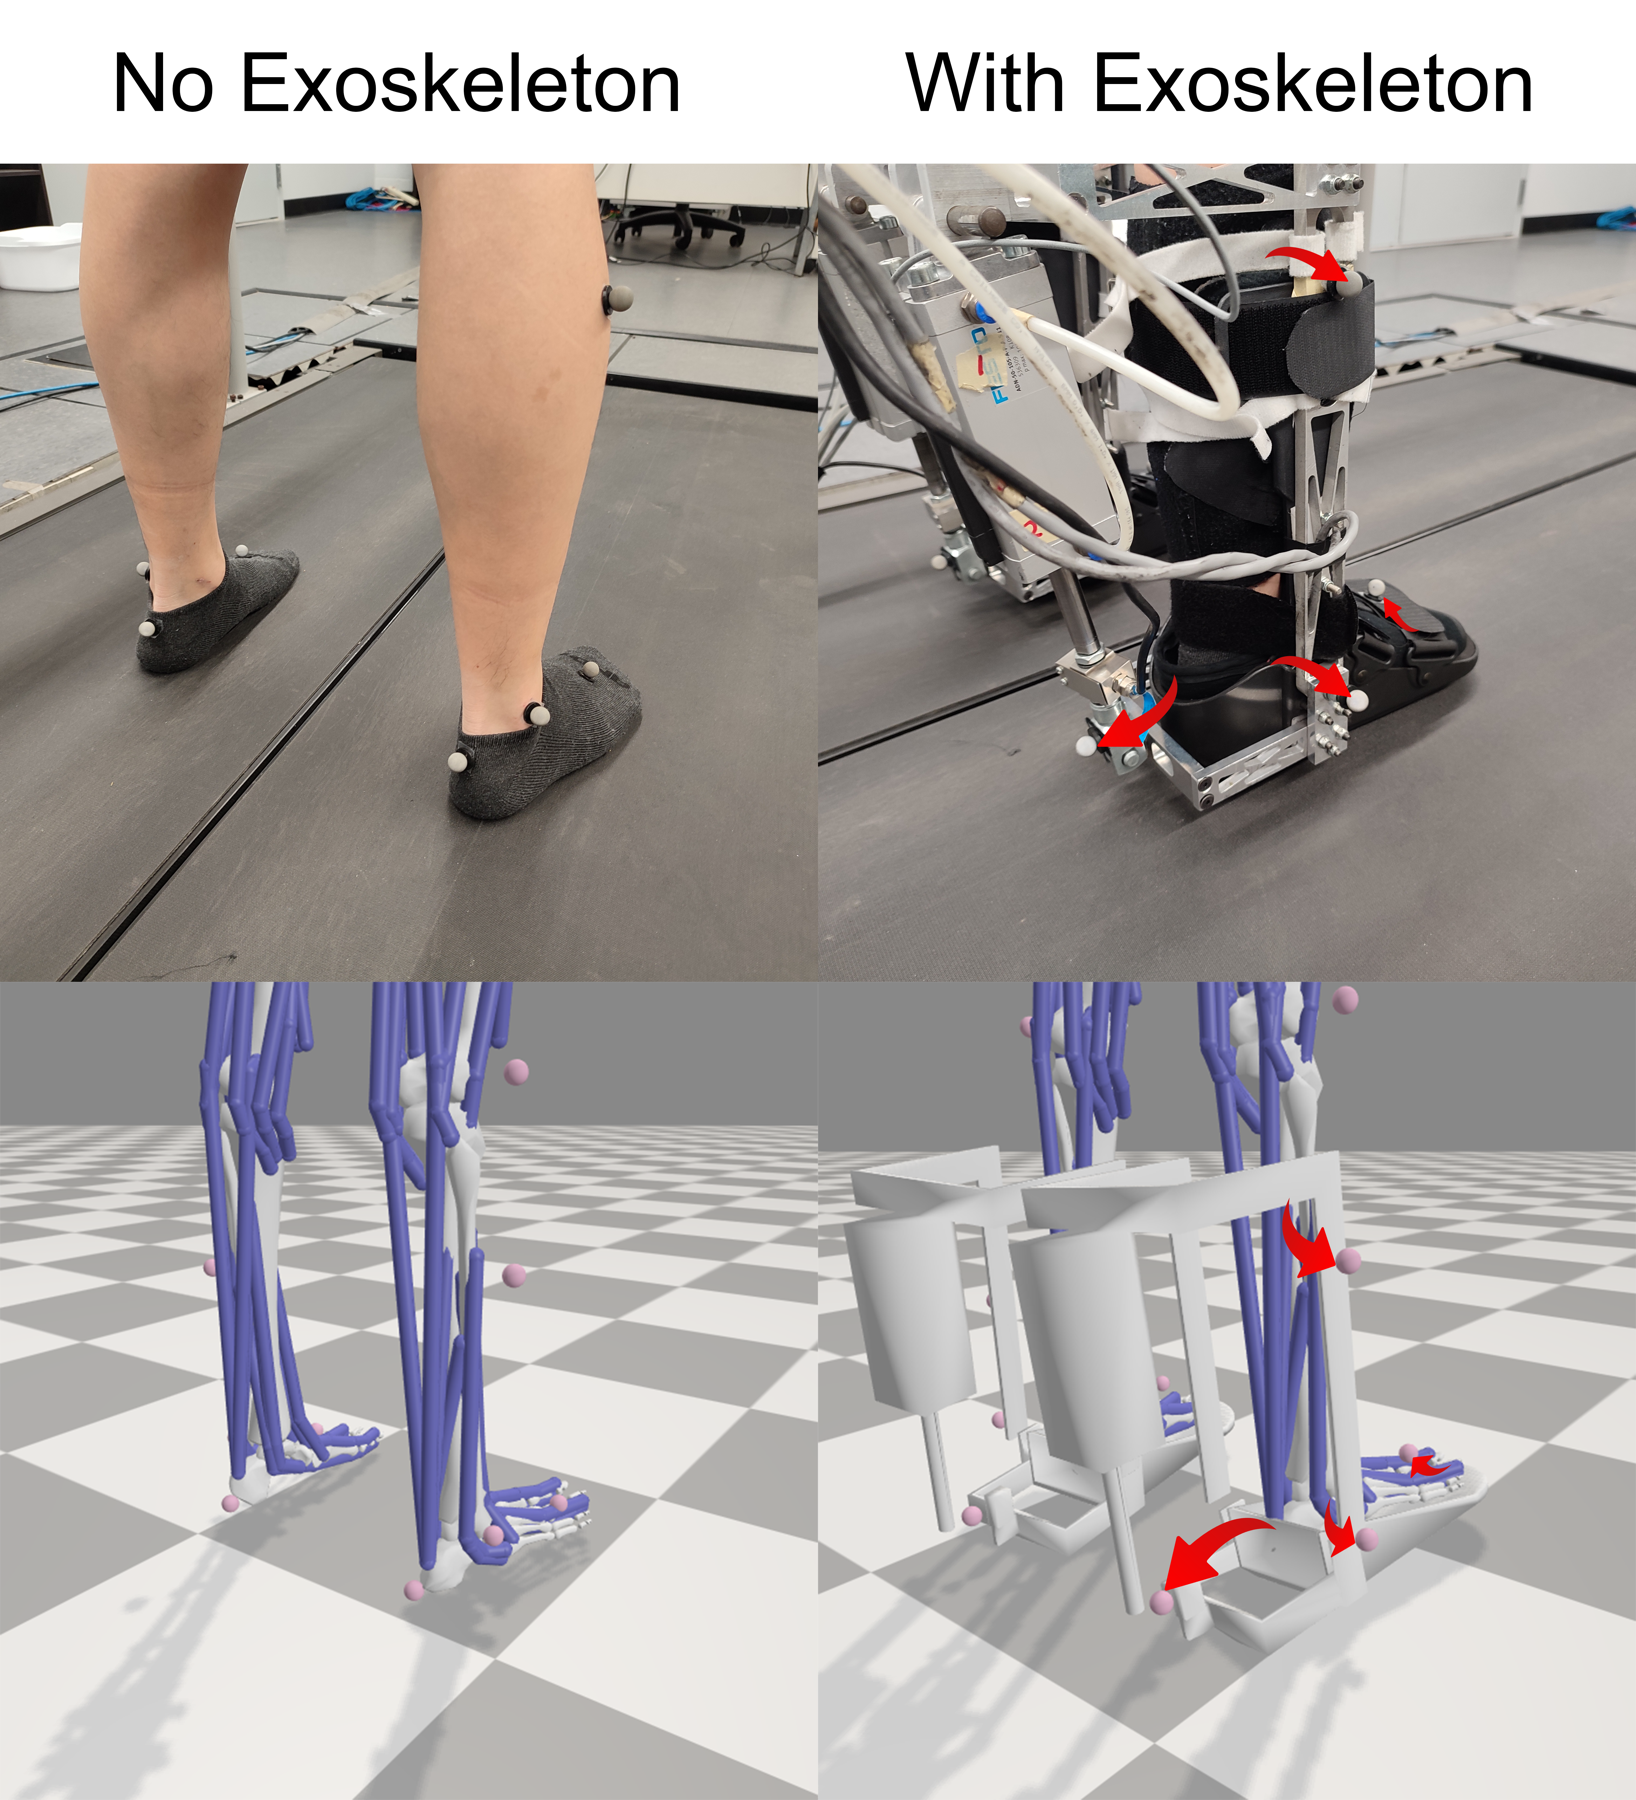
Wearing an exoskeleton changes marker placement, so Vicon motion-capture data require adaptations beyond a conventional human-only model. Custom exoskeleton–musculoskeletal models support inverse kinematics (IK) and inverse dynamics (ID) in OpenSim.
MATLAB conversion and batch-processing scripts connect Vicon measurements to OpenSim analyses, supporting data processing, verification and repeated analysis. Model comparisons, a simulation video, a sample batch-processing script and an inverse-dynamics tutorial are retained on this page.
Research roles: Xiaowen Chen developed gait-event detection methods, custom models and MATLAB processing workflows under the supervision of Anne Martin.
Research context
The Gait Optimization (GO) Lab at Penn State studies human walking and rehabilitation technologies, adapting robotics methods to human movement through optimization, control and mechanism design.
Gait Optimization Lab